
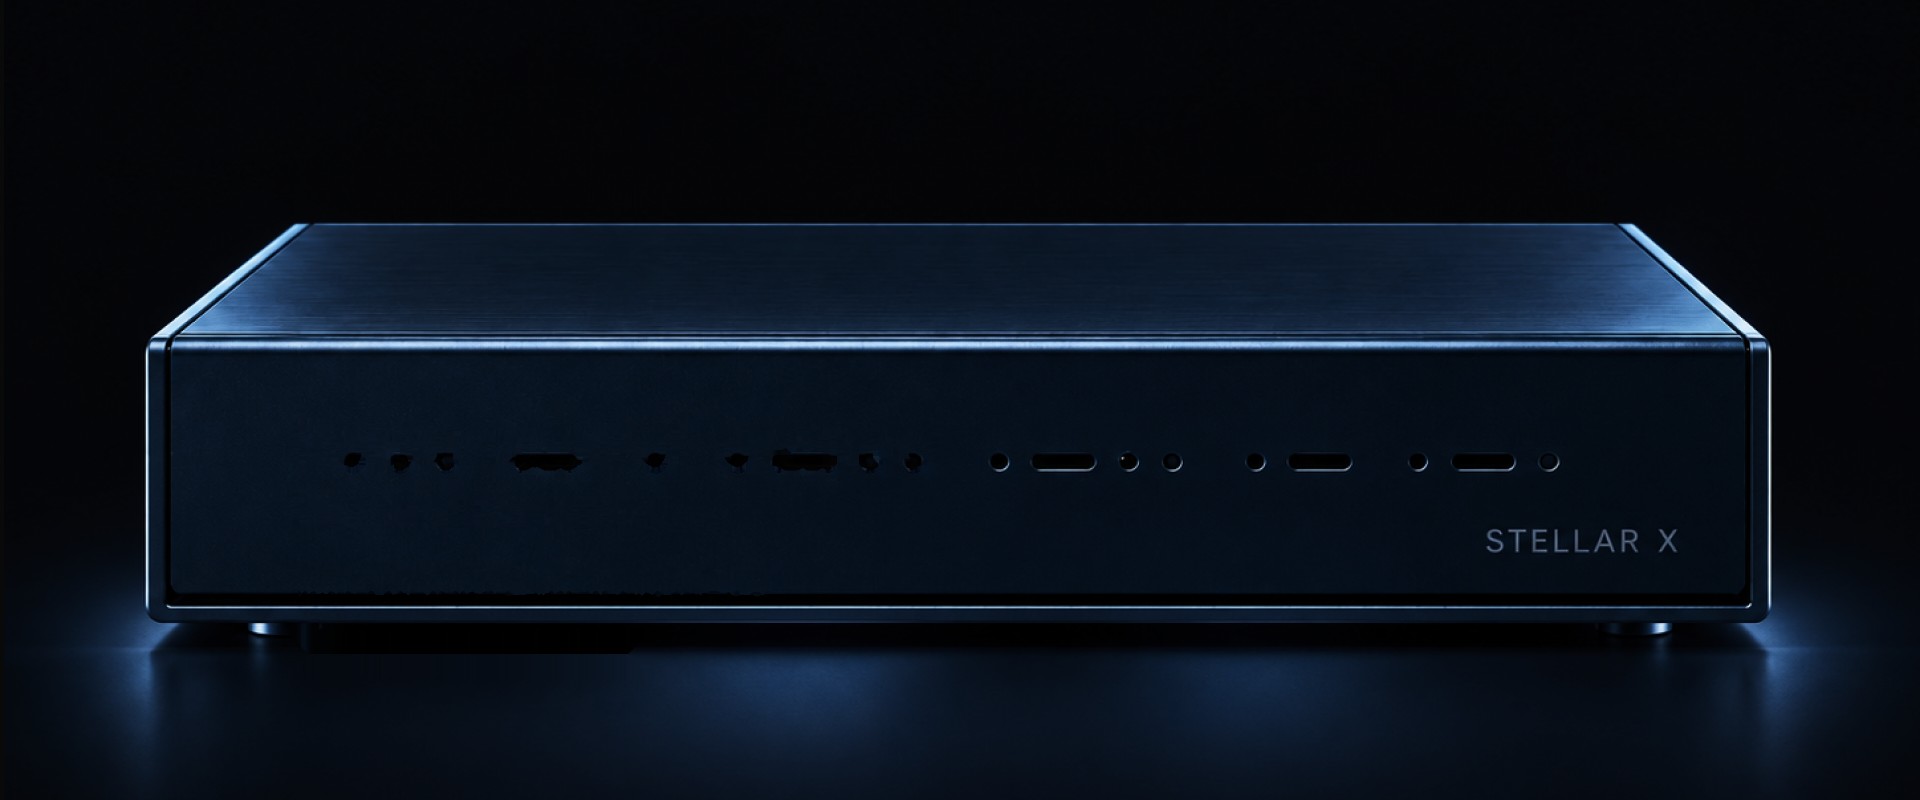
Robot control, definedby software.
An EtherCAT-based robot controller that brings software-defined robotics to life.Configure, deploy, and control real-world robotic systems with Stellar.
Why Stellar X
Control that adapts to yourdesign.
From industrial equipment to robotic arms and mobile platforms, Stellar X brings software-defined flexibility to EtherCAT-based control. Configure your system in software, reuse your control architecture, and adapt to different applications without starting from scratch.
Built for Different Applications
Control EtherCAT-based actuators across a wide range of systems, from industrial machinery to complex robotic platforms.
Reconfigurable by Design
Define your system’s topology and control configuration in software. Adapt to different supported configurations without rewriting your control code.
Modular and Scalable
Build beyond a single controller. Connect multiple controllers through a modular architecture designed for complex, distributed control systems.
Software-defined control
One controller.Built around your software.
Stellar X uses Stellar Station as a shared, node-based environment for EtherCAT connectivity and control software. Choose the control software that fits your application, from industrial motion control to mobile robotics.
Stellar Station
A unified, node-based environment for configuring and running control systems. Connect Gateway and Controller nodes, manage system configurations, and execute control software.
Configure & Run
From configuration toreal-world control.
Build your control system in Stellar Station. Define your system, connect your EtherCAT hardware, and run your control software—all within a unified workflow.
Design & Hardware
Built to fit.Engineered to control.
Stellar X combines purposeful hardware design, dedicated connectivity, and an optimized embedded architecture in a controller built for robotic and industrial systems.
Specs
Model (STX-ECV2)
Computing & Performance
- Processor
- Quad-Core ARM 64-bit
- Memory
- 2 GB / 8 GB
- Operating System
- Real-Time Linux OS
- Control Cycle
- 1 ms (1 kHz)*
Control & Connectivity
- EtherCAT
- 1 × Port
- Ethernet
- 1 × Port
- Communication
- EtherCAT CoE / CiA 402
- Axis Support
- 1–7 axes (Motion)*
- 1-40 axes (Articulation)*
- 1-16 axes (Locomotion)*
- Safety Features
- Collision Detection
- Access Control
Mechanical & Electrical
- Dimensions
- 120 × 122 × 52 mm (4.72 × 4.80 × 2.04 in)
- Unit weight
- 614 g (1.35 lb)
- Power Input
- 24V DC
- Adapter Input
- 100-240 VAC, 1 Phase
- 50-60 Hz, 1.2 A Max.
- Environment
- Indoor Only
Software & Integration
- Runtime System Environment
- Stellar Station
- Manipulator Control
- Stellar Motion
- Articulation Control
- Stellar Articulation
- Mobile Control
- Stellar Strider
- Stellar Localizer
- Stellar Voyager
- Robot Definition
- Stellar Designer
- Gateway Definition
- Stellar Gateway Designer (EtherCAT)
- Gateway Definition
- Stellar Gateway Designer (EtherCAT)
- Gateway Definition
- Stellar Gateway Designer (EtherCAT)
- Virtual Simulation
- NVIDIA Isaac Sim integration
Compliance & Warranty
- Compliance
- KC
- CE
- RoHS
- FCC
- Hardware Warranty
- 1 year
- Software Updated
- OTA Updates included*